Max Depth
Trusted by Partners
We build the future of marine autonomy: developing cutting-edge surface boats, tethered ROVs, and fully independent AUVs that leverage AI and real-time sensor fusion to execute intricate underwater missions.
An AUV is an untethered, fully intelligent robotic submarine engineered to operate independently in dynamic marine environments. Acting as its own captain, it relies on an onboard computational stack and an integrated sensor suite to map its surroundings, adapt to changing underwater conditions, and execute precise mission objectives—such as pipeline tracking or target localization—without a single line of communication to the surface.
An ROV is a highly maneuverable, tethered robotic submarine designed for deep-subsea intervention where human presence is impossible but human oversight is critical. Connected to pilots on the surface via an umbilical cable that streams high-bandwidth video and telemetry, it combines real-time human intuition with stabilized thruster control and robotic manipulators to perform delicate, complex tasks like underwater inspection, maintenance, and heavy tool operation.
An ASV is an intelligent surface craft optimized for long-endurance marine deployment and boundary-layer exploration. Operating at the intersection of air and water, it utilizes GPS, radar, and real-time environmental sensors to plot optimal paths, avoid obstacles, and survive rough sea states, serving as a vital communication relay, data aggregator, or aerial drone launchpad for underwater operations.
Multidisciplinary teams collaborating to push the frontiers of autonomous underwater robotics.
Built to defy immense underwater pressures. We design hydrodynamic hull structures, optimized multi-axis thruster layouts, and custom manipulation tools to turn complex CAD concepts into rugged, ocean-ready robots.
Explore DivisionThe vital bridge between data and action. We design custom PCBs and hardware interfaces utilizing IMUs and pressure sensors for precise depth tracking, backed by smart power circuits for safe battery regulation.
Explore DivisionThe cognitive core of our vehicles. We build integrated frameworks for Perception (computer vision object tracking), Autonomy (real-time path planning), and Control Systems that allow our bots to navigate the depths completely on their own.
Explore DivisionExploring the technologies that push autonomous marine systems forward. We research, prototype, and validate new approaches in robotics, sensing, navigation, and intelligent underwater systems for the next generation of our vehicles.
Explore DivisionDriving the team's external partnerships and growth. We manage industry collaborations, sponsorships, outreach, and strategic relationships that connect DTU AUV with organizations shaping the future of marine technology.
Explore Division
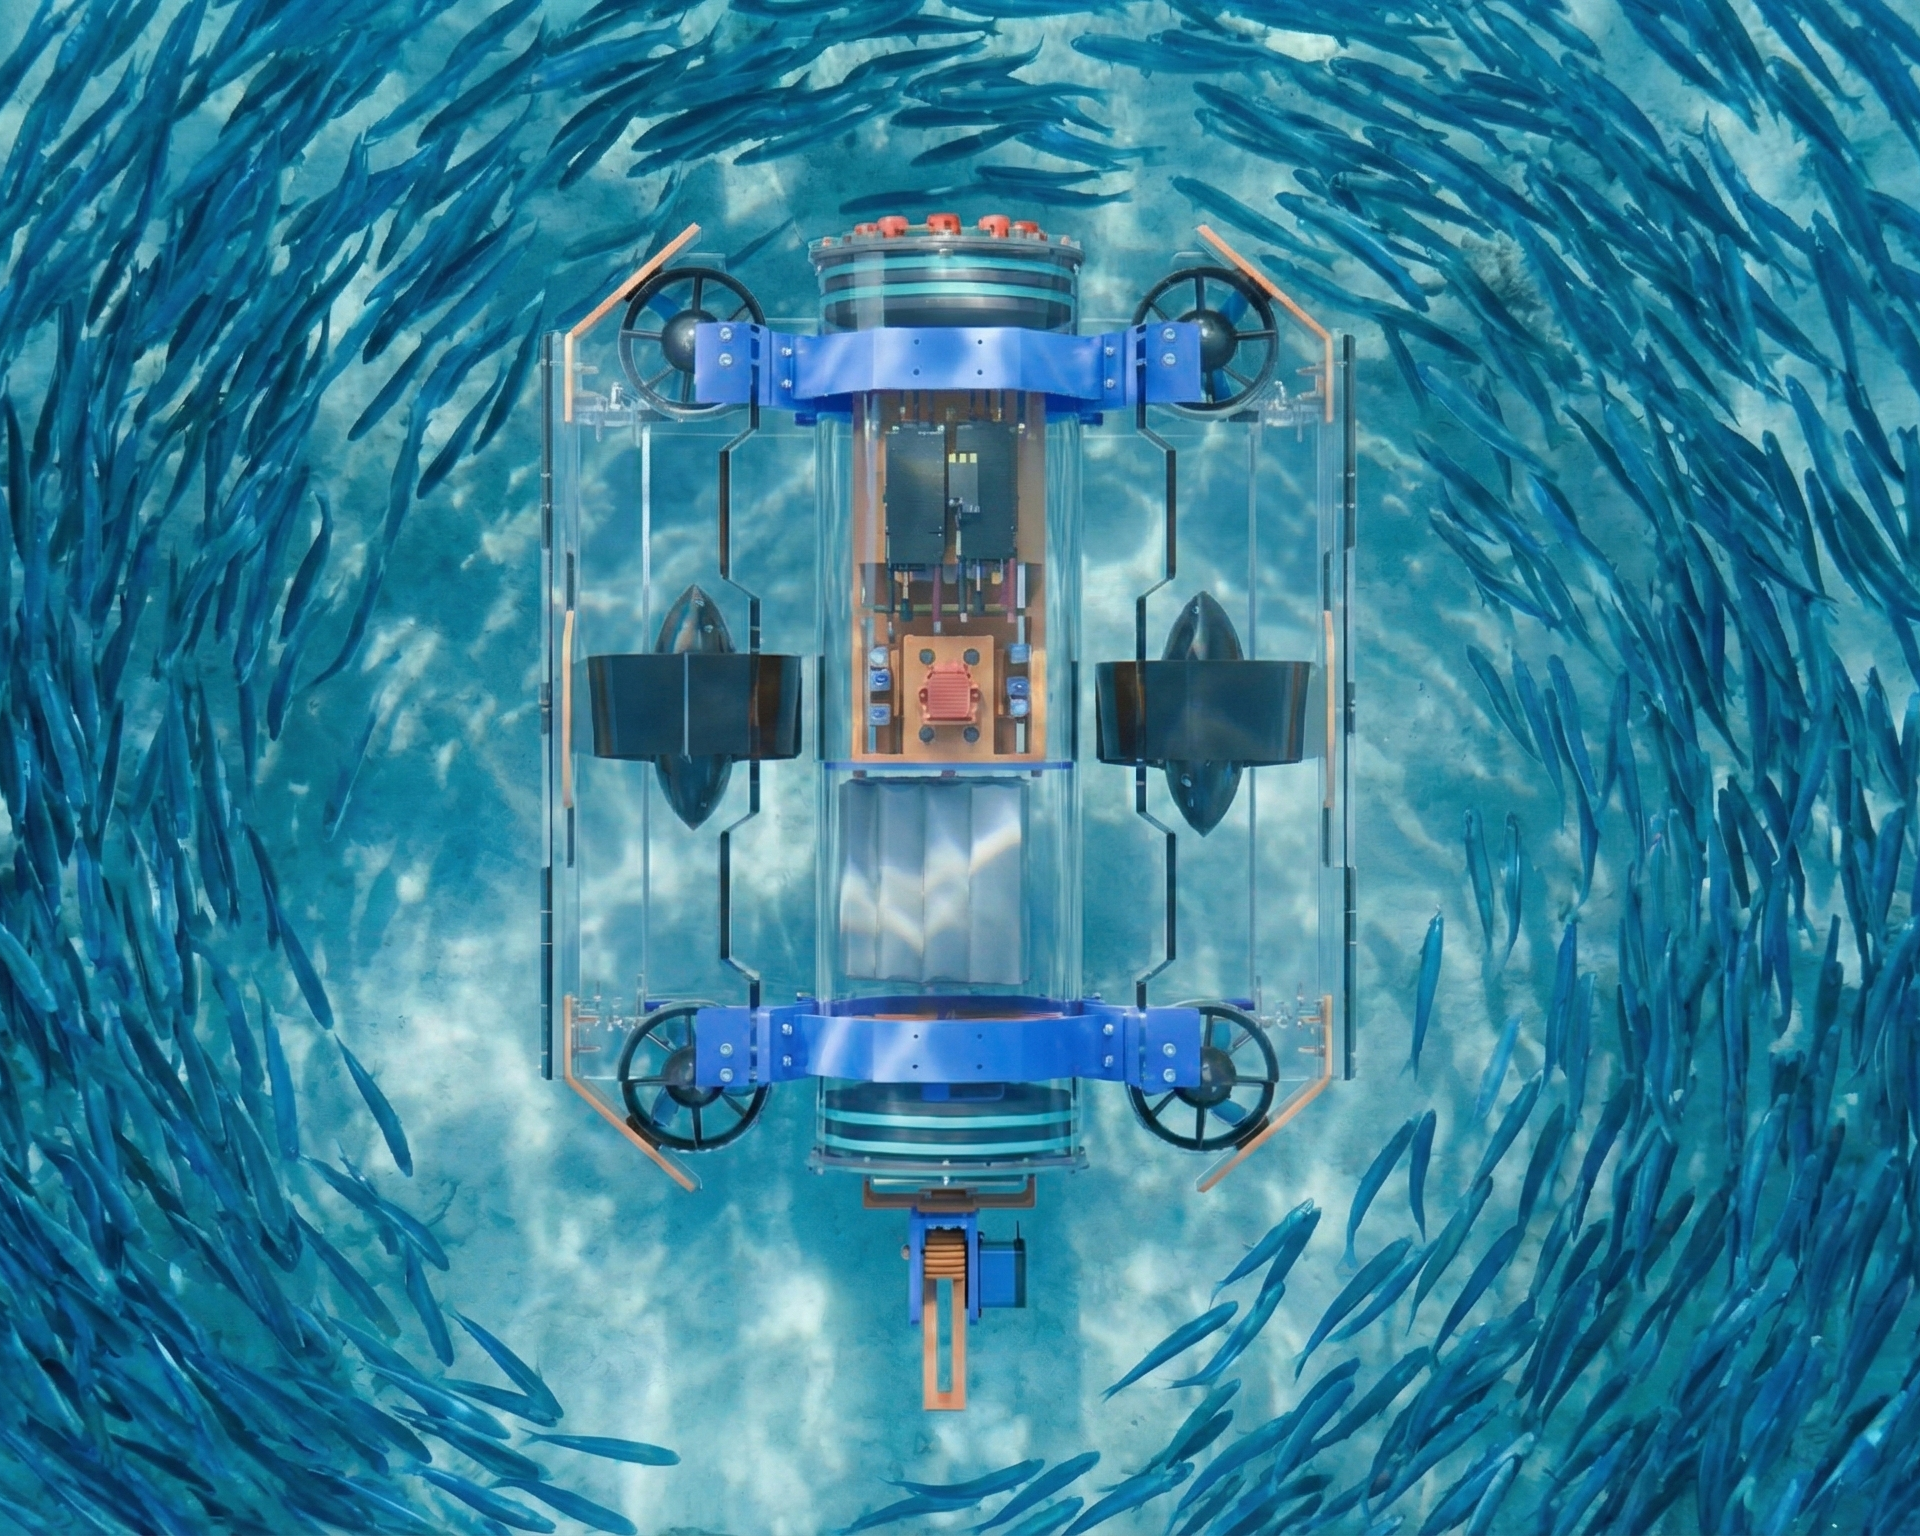
LAPRAS 2.0 is DTU AUV's second-generation autonomous underwater vehicle built for the SAUVC competition. Featuring a streamlined hull, enhanced thruster configuration, and an upgraded vision pipeline, it pushes the boundaries of underwater autonomy.
Learn MoreHear from team members and mentors who have witnessed the evolution of our autonomous underwater vehicles. Discover how our multidisciplinary approach to robotics and engineering is shaping the future of marine exploration.
"Working on LAPRAS 2.0 taught me more about embedded systems than any classroom ever could."
"The AI navigation system we built for ARKAJA 2.0 achieves real-time obstacle avoidance at depth."
"You win some, and you lose some, but you always learn a lot."
Design and pilot a Remotely Operated Vehicle in Delhi Technological University's flagship underwater robotics competition.
Registration closes on 10th September. Open to school, college & industry teams.